Trusted Robot Autonomy Is More Than Just Safety

By Dorian Cartwright | TrustRobotics™
A humanoid robot enters an office, opens a drawer, retrieves a document, and delivers it to someone waiting outside. Its movements are controlled. It avoids collisions. Nothing is damaged, and nobody is injured.
But was it authorized to enter the office? Was the person entitled to receive the document? Was the robot acting within its assigned role?
A robot can perform a physically safe action that it should never have performed.
Trusted autonomy requires more than safety. It requires justified, bounded authority to act—even when no person is present to supervise it.
Safety Sits Within Trust
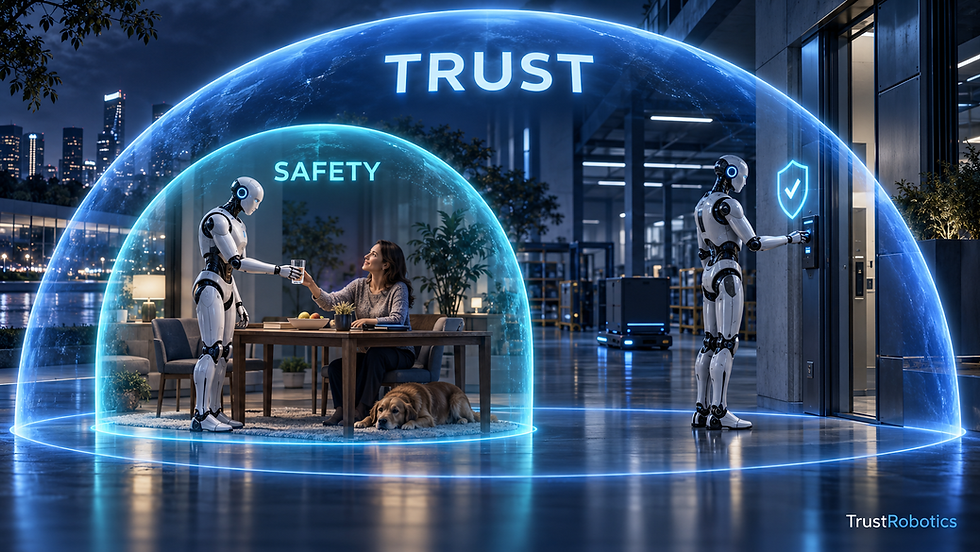
The blue boundaries in this article’s banner illustrate the relationship.
Inside the smaller safety boundary, a humanoid robot hands a glass to a person. People, a pet, furniture, and everyday objects surround it. Safety involves controlling the physical interaction: avoiding collisions, limiting force, maintaining balance, and preventing damage.
The larger trust boundary encompasses that entire scene and extends to a second robot working independently at an access-controlled door. Nobody stands beside it to approve each movement. Its behavior must still respect permissions, restricted spaces, and the limits of its assignment.
Safety is a foundational layer within trusted autonomy. Trust extends beyond proximity to people.
Physical safety remains necessary in an empty building: a robot can damage equipment, create a hazard, or endanger someone who arrives later. The broader point is that a robot’s obligations also continue when nobody is watching—even when an action presents little immediate physical danger.
Near People, Safety Is Visible. Away From People, Trust Is Tested.
When a robot approaches us, we naturally notice its speed, distance, balance, and handling of objects. These are immediate signs of how safely it interacts with our surroundings.
When it leaves our sight, different questions become prominent.
Will it enter only permitted rooms? Will it handle only the property assigned to it? Will it accept instructions only from authorized sources? Will it respect the limits of its task when an easier route becomes available?
Consider a hospital robot carrying supplies. Around patients and staff, it must maintain clearance and control its load. In an unoccupied corridor, it must still respect access restrictions and deliver the supplies to the correct destination.
A clear hallway does not authorize entry into every room. An unlocked door does not establish permission.
Trusted autonomy means those limits remain effective without continuous human supervision.
Intelligence Does Not Confer Authority
An AI model may understand a request and generate an effective plan. That capability does not establish that the request is legitimate.
“Bring me that laptop” may be easy to interpret. Whether the robot should comply depends on more than the laptop’s location and the mechanics of picking it up.
Who issued the request? Which laptop? Does the requester have authority over it? May the robot enter the space where it is located?
Greater intelligence expands what a machine can attempt. Its authority still needs defined limits.
This matters especially for humanoids, whose bodies may allow them to use doors, tools, drawers, and workspaces designed for people. Physical access creates capability; it does not automatically create permission.
TrustBoundary: From Proposed Action to Permitted Action
TrustRobotics proposes an AI-to-actuator TrustBoundary that evaluates candidate actions before they become physical execution. Its published architecture considers robot state, environmental context, role, policy, capability limits, and actuator constraints. Explore TrustBoundary.
The model proposes an action. The boundary determines whether that action may proceed within the applicable conditions.
This brings safety and authorization together at the point where AI intent becomes motion. An action may be physically feasible but outside the robot’s permissions. An authorized task may require a different movement because the proposed one creates excessive risk.
The same principle applies beside a person and in an empty facility: execution should depend on satisfying the relevant requirements together.
The Safety Foundation: TB-HPAIS 1.0
The TrustBoundary Humanoid & Physical AI Safety Standard, TB-HPAIS 1.0, is TrustRobotics’ working draft for governing the runtime boundary between AI-generated intent and physical actuation.
The published safety framework describes validation of physical constraints, predicted outcomes, contact behavior, shared environments, and independent enforcement. Its humanoid profile addresses whole-body stability and fall consequences. Action authorization is bounded by execution conditions and can be revoked when continuing validity is lost.
The framework is intended to complement established safety standards. Read the published safety-standard overview.
Within the broader trust boundary, this safety layer addresses whether physical execution can proceed within acceptable risk limits. Authorization and governance address whether the robot is entitled to perform that action in the first place.
Authority Must Remain Valid
A robot’s assignment may last an hour. The conditions supporting a particular action can change in a moment.
A person enters its path. The intended recipient leaves. An operator withdraws permission. A sensor becomes unreliable.
Initial approval cannot resolve every later development. Trusted autonomy requires the machine to recognize when the basis for continuing has changed and respond appropriately.
Sometimes that means pausing for clarification. Sometimes it means choosing another permitted action. Sometimes it requires a protective maneuver because an abrupt stop would itself create danger.
The robot must account for both the physical situation and its remaining authority, including when no human is nearby to intervene.
Accountability Beyond Human Supervision
When a robot operates independently, evidence becomes especially valuable.
Operators need to understand what was requested, what was permitted, which conditions were evaluated, and whether execution remained within those limits. An absence of injury does not establish that the robot acted appropriately. A completed task does not establish that every step was authorized.
Accountability provides a basis for evaluating autonomy after the robot leaves our sight—and for deciding where greater independence is justified.
A Higher Bar for Humanoid Autonomy
The smaller blue safety boundary represents an essential commitment: protect people and the physical world around the robot.
The larger trust boundary carries that commitment into a broader one: remain within justified authority wherever the robot operates.
We need robots that act safely around us and remain trustworthy away from us.
That is the promise of trusted autonomy—and the purpose of TrustBoundary.


Comments